Here is a comprehensive collection of my work in precision mechanism design, robotics, and autonomous systems.
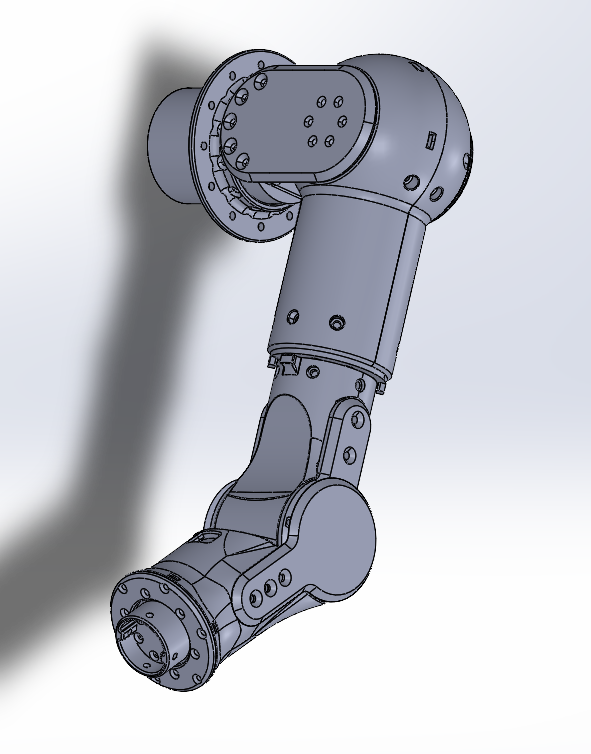 Humanoid Robotics 7+ DOF Arm & Harmonic Drives |
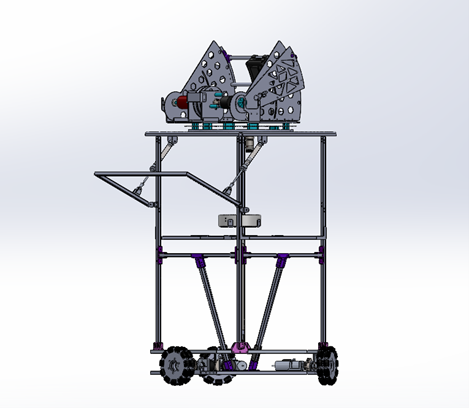 ABU Robocon 2025 Competitive Robotics |
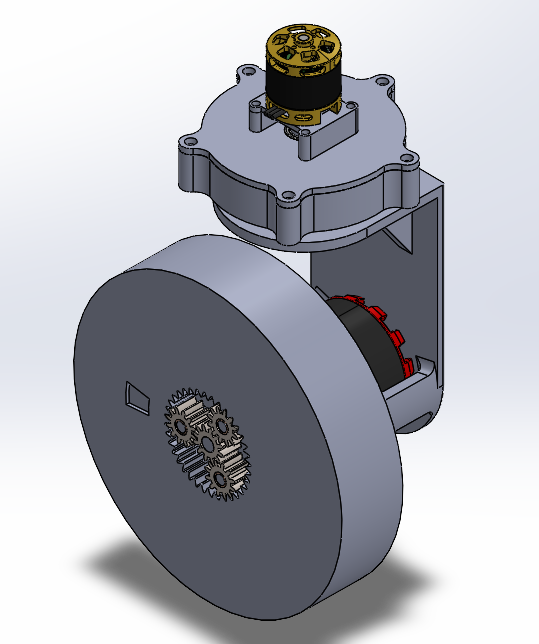 B.Tech Project: Heavy-Duty Swerve Drive Industrial Mobility System |
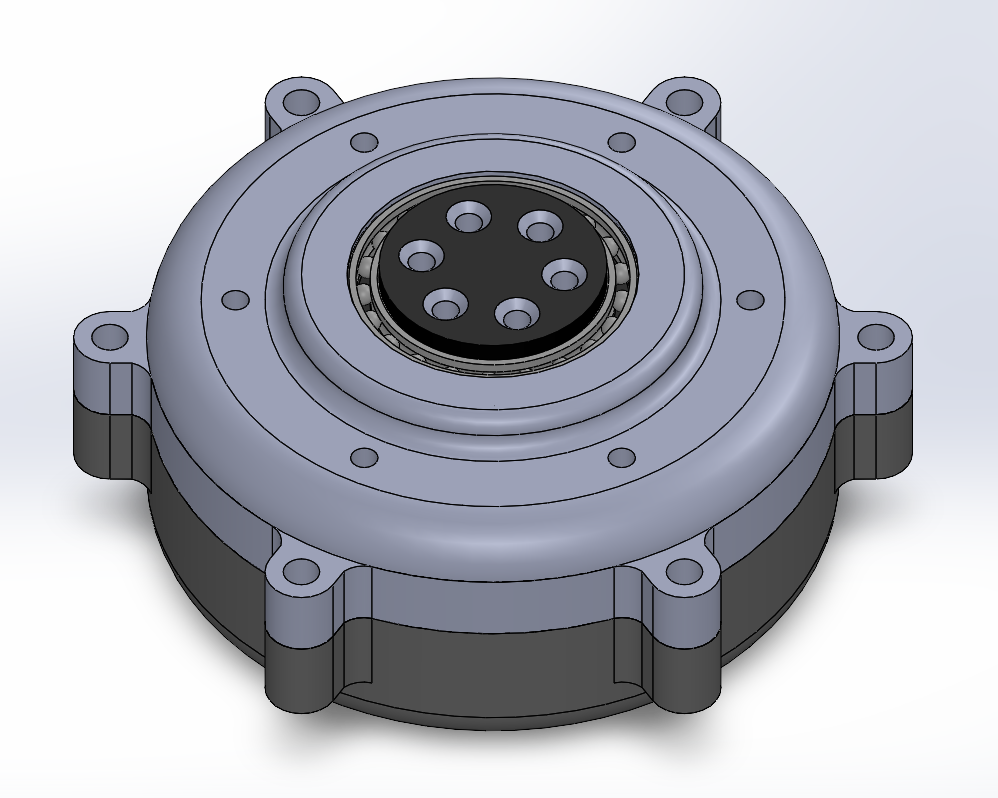 Hybrid Actuator (106:1) Planetary-Cycloidal Design |
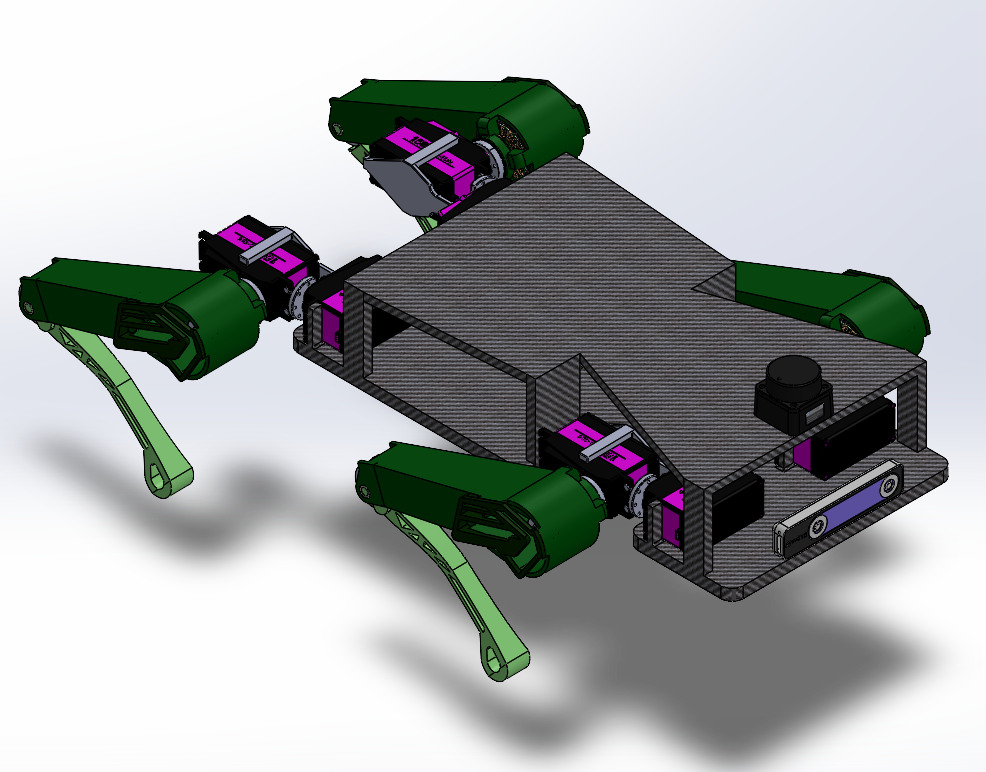 Quadruped Robot Mechanical Assembly & MuJoCo |
 Autonomous Surface Vessel Marine Navigation & Logistics |
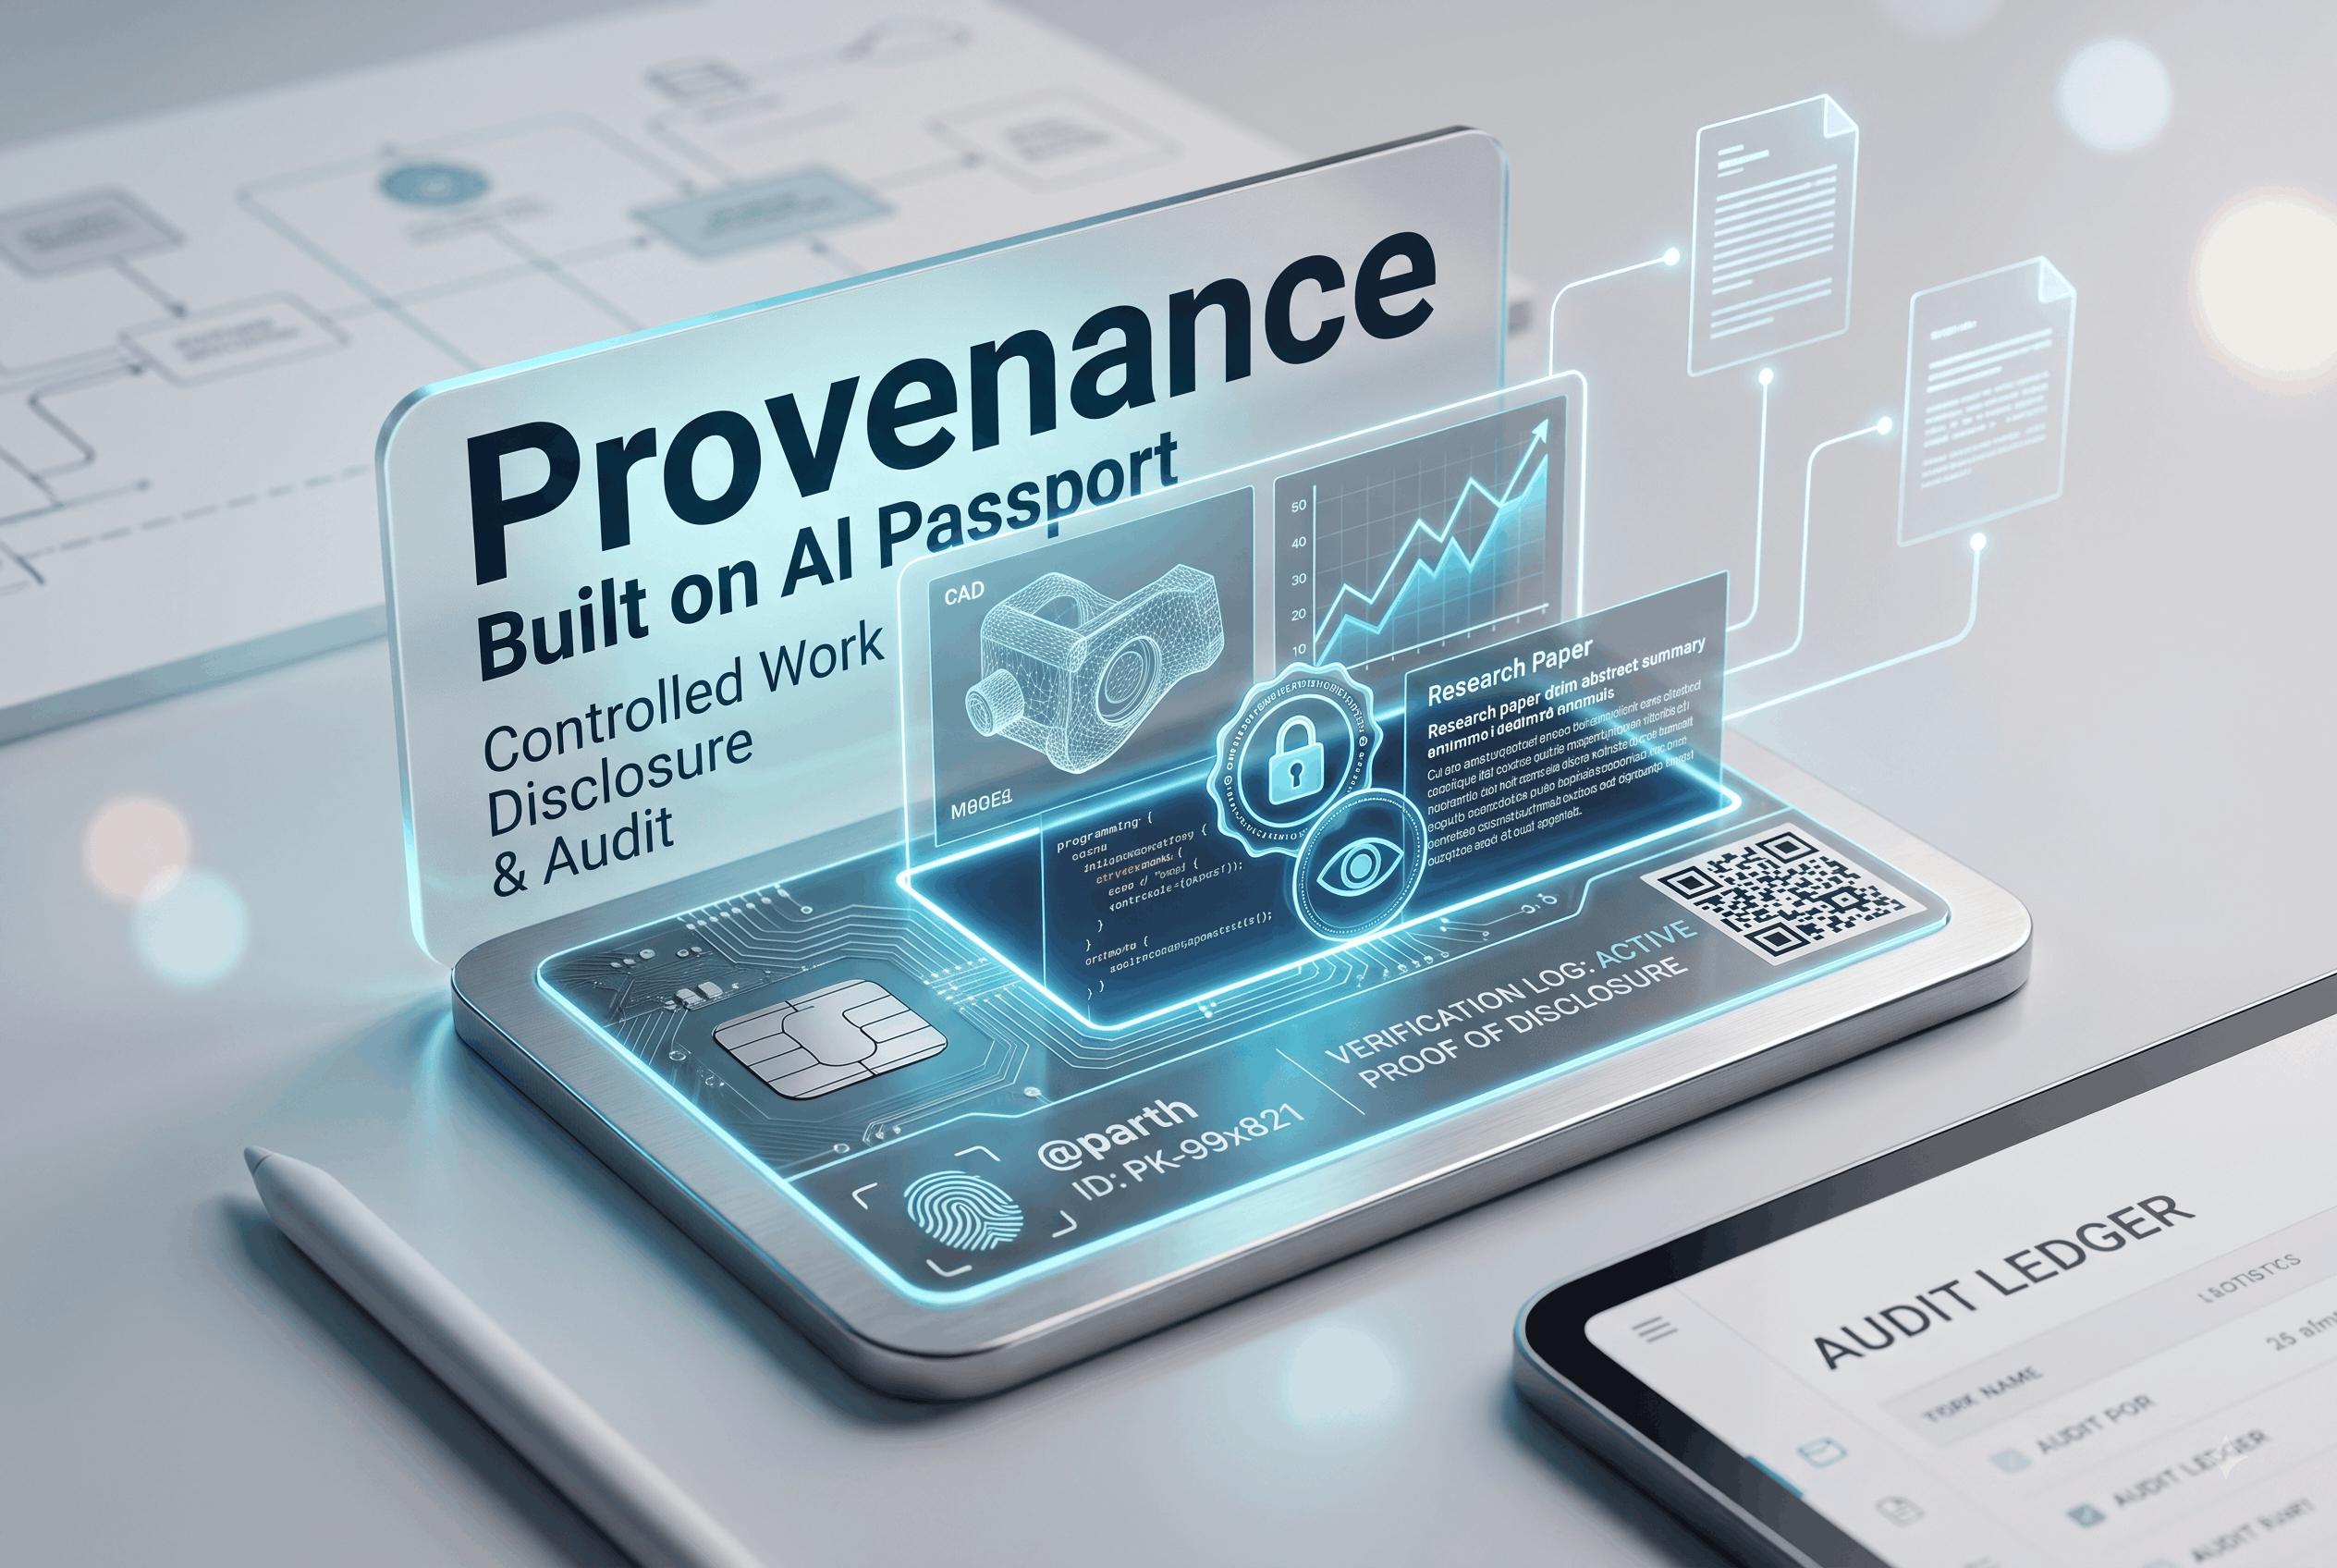 Provenance | IP Management Cryptographic Engineering Dashboard |
Technical Project Specifications
Humanoid Robotics & Applied Actuation (Techligence Pvt. Ltd)
May 2026 – July 2026
- Kinematic Architecture: Designing a 7+ DOF anthropomorphic robotic arm using a mixed actuator architecture—cycloidal actuators at high-load proximal joints, harmonic drives at mid-joints, and custom spur gear servo motors at distal joints.
- Constraint Modeling: Researching harmonic drive implementations to optimize joint torque density and backdrivability, utilizing flexspline radial deflection and bending stress analysis as primary design constraints.
- Subsystem Execution: Owning the full design-to-validation cycle for humanoid receptionist robot mechanical subsystems, including rigorous tolerance stack-up analysis, rapid prototyping, and functional hardware testing.
Dynamic Jumping Mechanism (Robocon 2025)
September 2024 – July 2025
- Hardware Iteration: Designed and owned a cam-actuated jumping mechanism, engineering an increase in jump height from 10 cm to 21 cm through successive hardware iterations targeting spring preloading, cam geometry, and release timing.
- Structural Isolation: Designed the main chassis to withstand repeated dynamic jump-and-land loading cycles, integrating targeted structural isolation to completely prevent impact load transmission to onboard electronics.
Heavy-Duty Modular Swerve Drive System
December 2025 – Present
- Load Specifications: Developing a highly compact, omnidirectional swerve drive module explicitly engineered for a 25 kg payload at an FOS of 2, aimed at industrial mobility platforms.
- Mechanical Integration: Directly responsible for the system's structural layout, gear ratio selection, and bearing specifications; successfully integrating a custom planetary gear mechanism for steering actuation with a high-torque wheel drive axis.
Compact High-Torque Actuator (Planetary-Cycloidal Hybrid)
November 2025 – January 2026
- Analytical Sizing: Designed a 70 mm, 105.88:1 actuator combining a planetary input stage with a 25:1 cycloidal output. Sized all gear geometry analytically to distribute contact loads and minimize localized tooth wear using the hunting tooth principle.
- Research & Validation: Offset the backlash limitations of planetary drives against the manufacturing complexity of cycloidal drives. Validated structural adequacy through hand calculations prior to CAD. Presented at ICASET 2026.
SPOT-Inspired Quadruped & MuJoCo Kinematics
January 2024 – Present
- Mechanical Assembly: Designed a complete quadruped mechanical structure in SolidWorks, heavily prioritizing leg geometry for static stability, modular joint configurations, and variable terrain adaptability.
- Physics Simulation: Building custom kinematic models from scratch in MuJoCo, enforcing strict joint torque constraints and stability criteria to train physical AI locomotion policies via reinforcement learning.
Autonomous Surface Vessel (ASV) for Marine Navigation
June 2026 – Present
- Mechatronics & Propulsion: Designing the hull layout, propeller drive control, and gyroscopic stabilization systems to guarantee dynamic stability under severe riverine and marine current loads.
- Sensor Integration: Interfacing the onboard autopilot system with a comprehensive sensor suite (GPS, IMU, LiDAR, Ultrasound) to facilitate fully autonomous operation and real-time dynamic collision avoidance.
Provenance | Cryptographic IP Management
Frontend Development & Systems Security
- Granular Access Control: Developed a conceptual frontend architecture allowing modular, fine-grained access to proprietary engineering assets, bridging the gap between mechanical design and digital security.
- Session Security & Auditing: Integrated simulated dynamic session watermarking and cryptographic audit receipts to track viewer history, monitor escrow gates, and prevent unauthorized data extraction.