Heavy-Duty Modular Swerve Drive System
B.Tech Major Project | December 2025 – Present
Developing an omnidirectional swerve drive module specifically engineered for industrial and vehicular mobility platforms. The system scales up previous swerve concepts to meet severe structural and torque demands, operating within a highly constrained module envelope.
Mechanical Layout & CAD Modeling
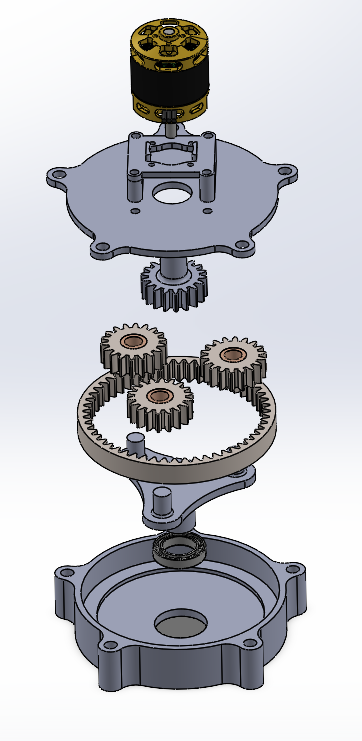
Fig 1: Exploded view detailing the integrated planetary steering and high-torque wheel drive layout.
Load Specifications & Kinematics
- Payload Rating: Designed and rated for a 25 kg payload at a structural Factor of Safety ($FOS=2$), ensuring reliability under industrial deployment conditions.
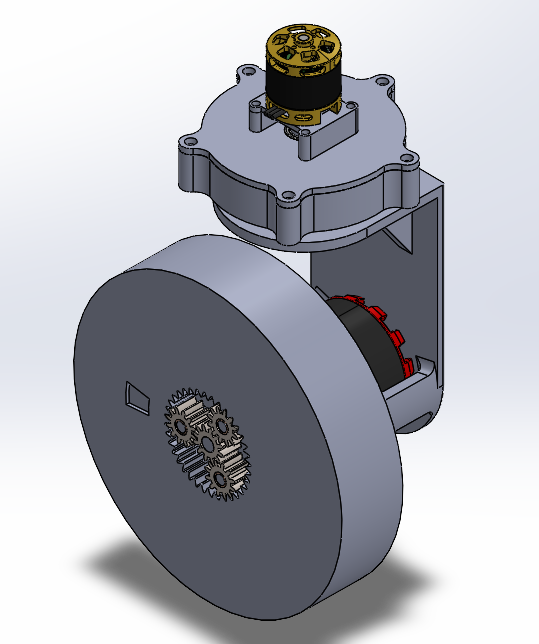
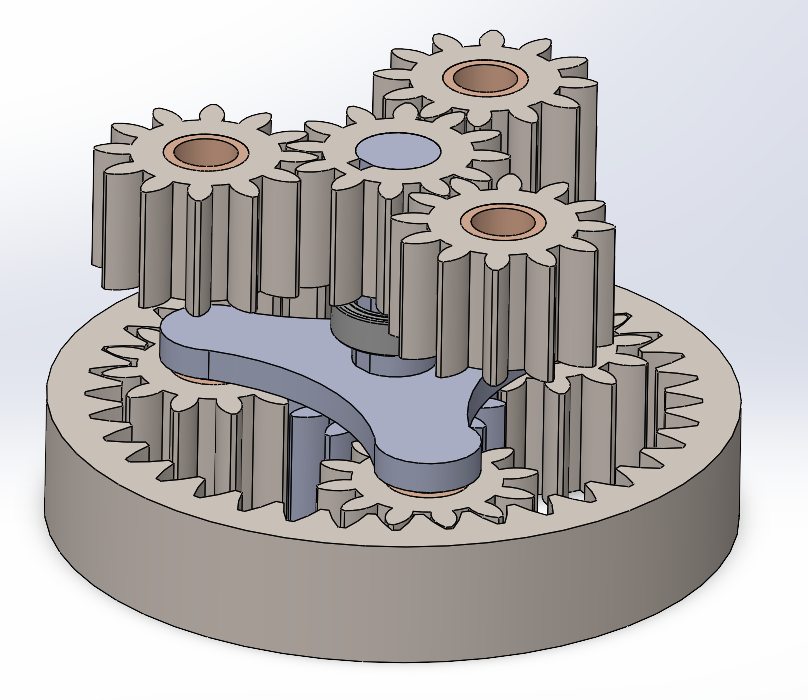
- Planetary Integration: Successfully integrated a custom planetary gear mechanism specifically for steering actuation alongside a high-torque wheel drive axis.
Mechanical System Ownership
- Component Sizing: Held direct responsibility for the complete structural layout, optimal gear ratio selection, and critical bearing specifications.
- Packaging Constraints: Packaged both the drive and steering axes into a compact module envelope, requiring rigorous tolerance management and spatial optimization.
Current Progress & Hardware Execution
- Rapid Prototyping: Currently fabricating the initial physical prototype utilizing FDM 3D printing. Selected PETG as the primary structural material to ensure adequate tensile strength, layer adhesion, and impact resistance during preliminary movement and load testing.
- Actuation & Control Architecture: Integrating Brushless DC (BLDC) motors driven by Field-Oriented Control (FOC) to achieve precise, high-efficiency torque delivery and smooth low-speed dynamic maneuvering across the omnidirectional drive axes.