Overview
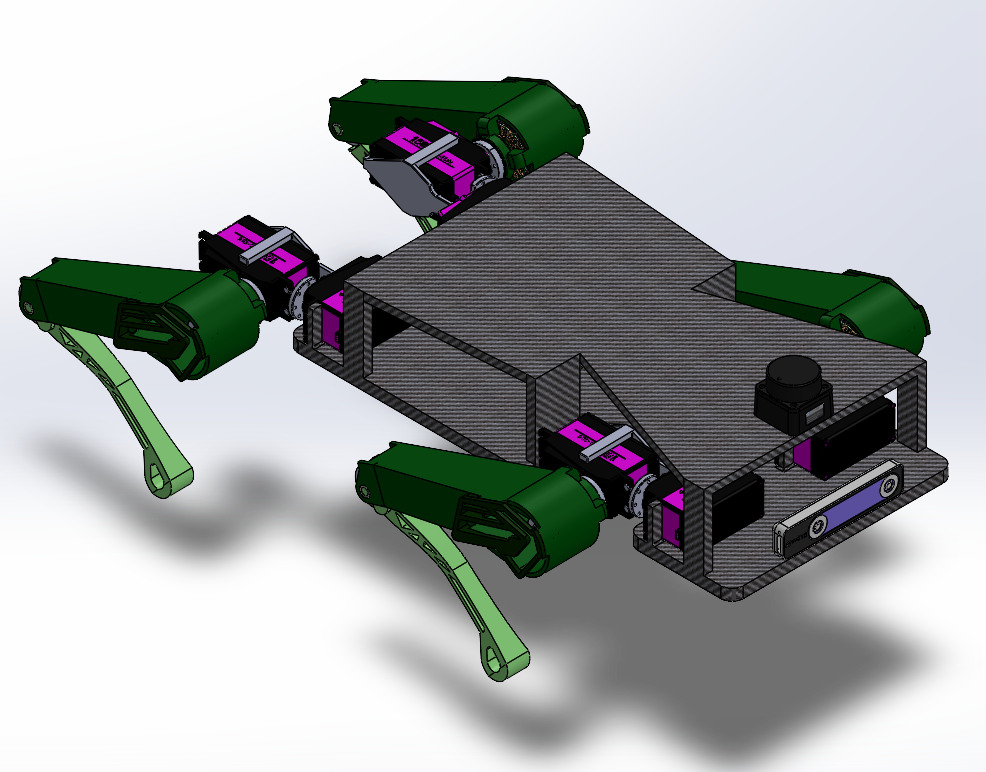
A purely mechanical quadruped platform designed to study power transmission, torque amplification, and actuation strategies in legged robots. Unlike typical servo-based quadrupeds, this system employs a hybrid actuation architecture to achieve higher torque density, improved efficiency, and better dynamic performance.
⚙️ Mechanical Design
The robot features a custom-designed leg drivetrain focused on robustness and precision:
- Primary Leg Drive: Actuated by BLDC Motors using a Timing Belt & Pulley system to reduce backlash, handle higher loads and improved torque-speed tradeoff.
- Position Feedback: Integrated Absolute Encoders at the output shaft (the joint) for precise position control without homing.
- Hip & Thigh: Actuated by high-torque servos for multi-degree-of-freedom movement.
💻 Simulation & Control
- Current Focus: Developing a ROS 2–based simulation using URDF and Gazebo.
- Objective : Validate kinematics, transmission behavior, and control strategies in simulation before hardware implementation.
📸 Component Gallery
| Isometric View |
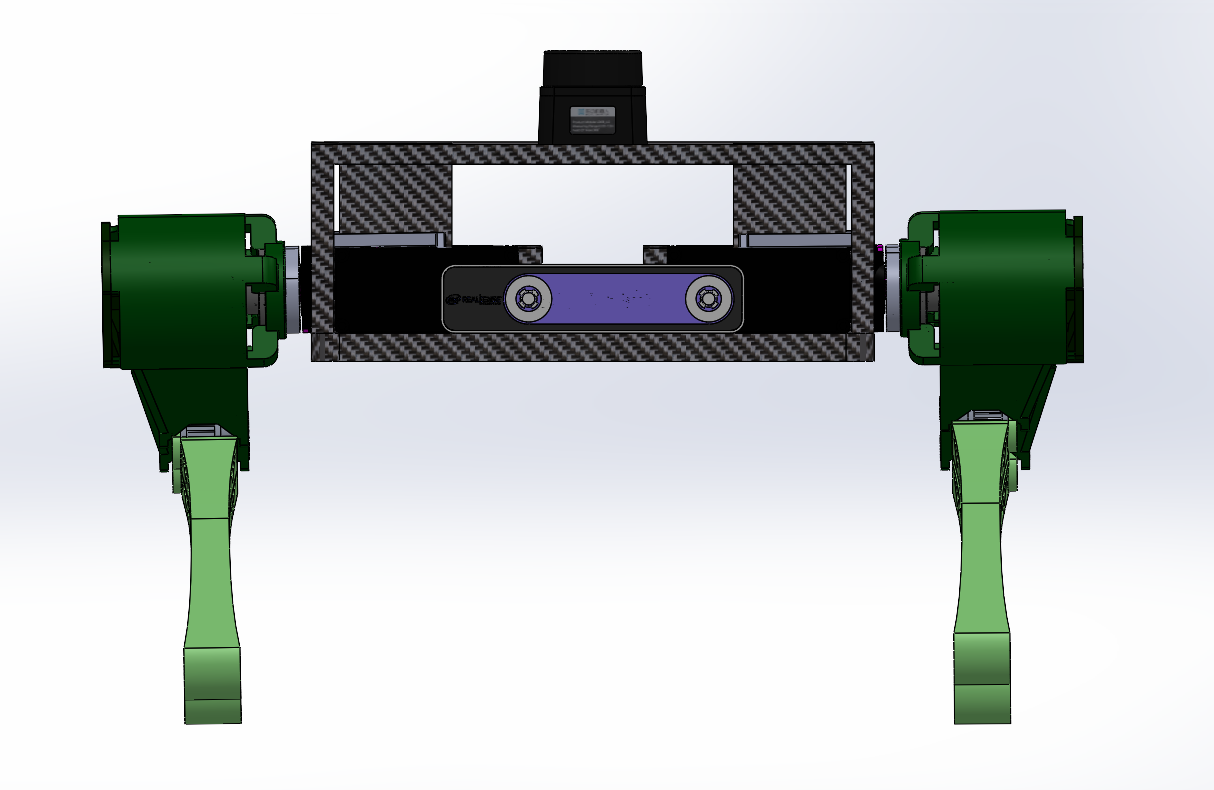 Front View |
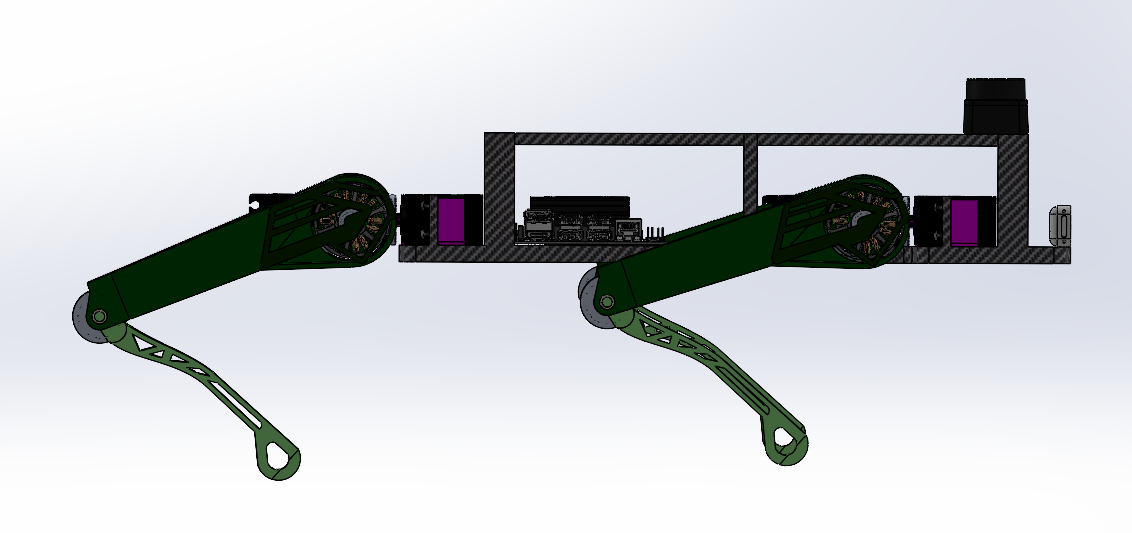 Side View |
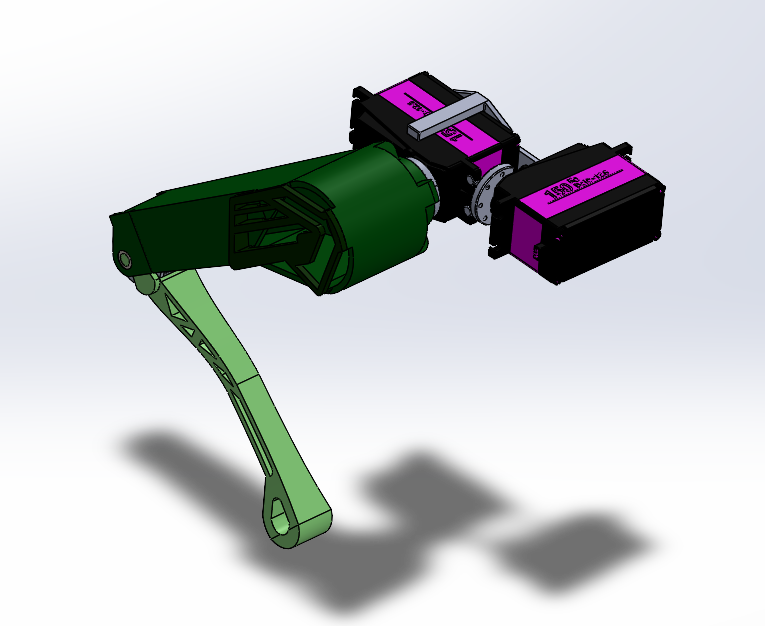 Leg Isometric View |
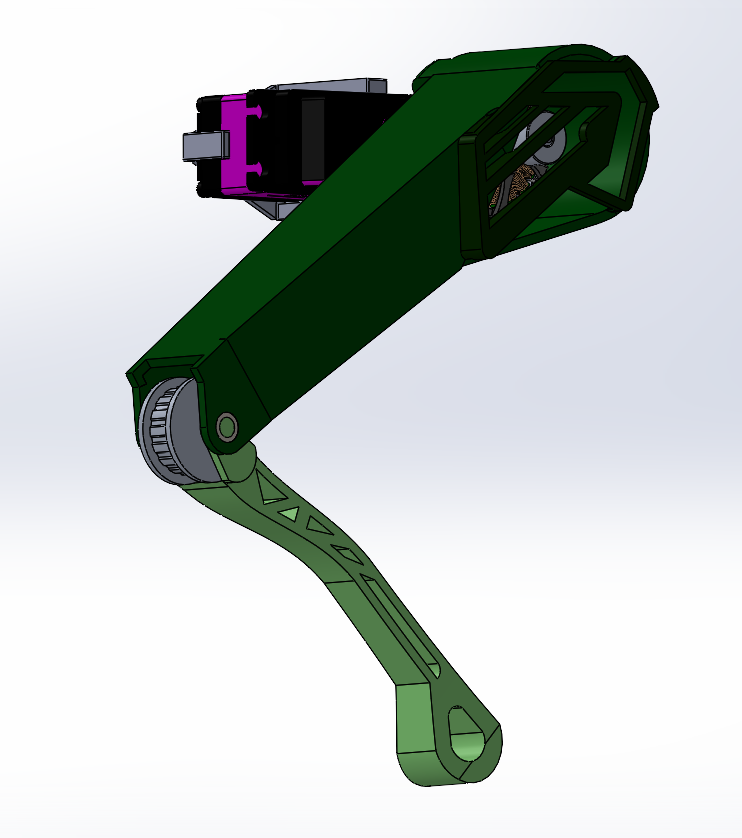 Leg Back View |