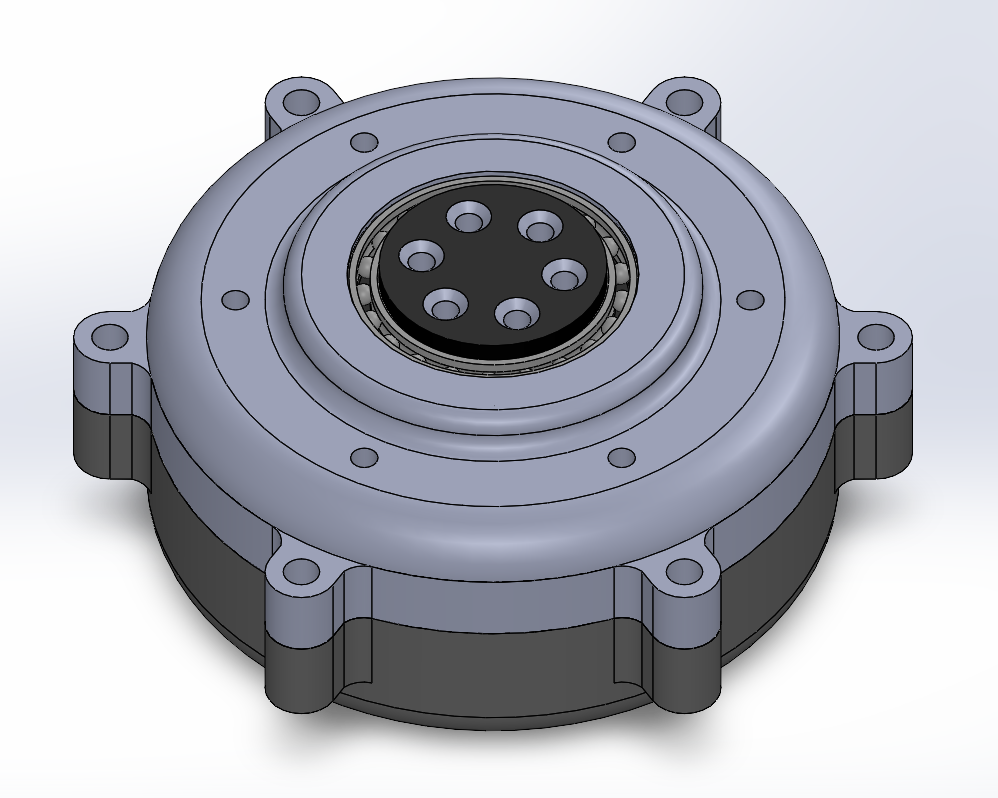
Project Overview
Status: Under Review for Conference Publication
I have designed a high-torque, compact rotary actuator tailored for robotic joints. The design addresses the “Length vs. Torque” trade-off by integrating complementary gear technologies into a single module.
Detailed specifications, architecture, and performance analysis are currently withheld pending the publication of the associated research paper.
- Application: Quadruped Legs, Exoskeletons, and Cobot Joints.
- Key Feature: High reduction ratio (106:1) in a compact axial form factor.