📘 ABU Robocon 2025 – Problem Statement (PS 2025)
- Competition: ABU Asia-Pacific Robot Contest 2025
- Theme: Robot Basketball
- Host: Ulaanbaatar, Mongolia
- Objective: Design and build autonomous/semi-autonomous/manual-operated robots that complete a basketball challenge (2v2), requiring tasks such as shooting, collecting, and passing balls within rule constraints on a contest field.
- Focus: Dynamic Game, Precision, coordination, autonomous control, and regulation-compliant performance.
🚀 Overview
Technical Team Member of the Robot Study Circle (COEP) for ABU Robocon 2025.
Contributed primarily to the mechanical subsystem, focusing on mechanism reliability,
structural stability, and on-ground robot readiness during development and competition.
- Role: Mechanical Design, Fabrication, Integration & Field Support
⚙️ Key Contributions
Jump Mechanism Development
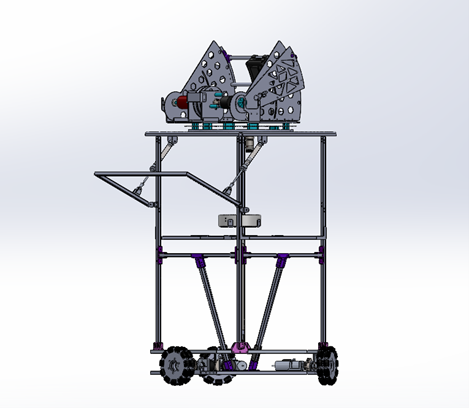
- Contributed to the design, iteration, and stabilization of the robot’s jump mechanism and base drive
- Focused on mechanical robustness and repeatability under dynamic loading conditions
- iterated from an initial 10\,cm jump height to 21\,cm through successive changes to spring preloading, cam geometry, and release timing against a revised target of 30\,cm.
In-House Manufacturing & Fabrication
- Majority of mechanical fabrication carried out in-lab
- Manual fabrication using hacksaws, bench drills, hand files, and fitting tools
- Extensive use of 3D printing for brackets, mounts, spacers, and rapid prototyping
- Vendor-sourced components limited to laser-cut plates and off-the-shelf gears
Structural Stability & Assembly
- Ensured chassis alignment, rigidity, and fastener reliability during aggressive maneuvers
- Performed continuous inspection, reinforcement, and mechanical maintenance throughout the season
Test Environment & Field Setup
- Designed and fabricated the complete test structure for Basket/hoop
- Built pillars, trusses, and mounting boards in accordance with official ABU Robocon dimensions
- Ensured repeatable and regulation-compliant testing conditions for mechanism validation
System Integration & Coordination
- Worked closely with the electronics team to provide proper mounting, protection, and cable routing
- Proactively ensured electronics-side requirements were met to avoid integration bottlenecks
🏁 Outcome
- Contributed to improving mechanical robustness, on-field reliability, and overall system readiness under competition constraints.
🎥 Match & Testing Footage
I have attached two videos demonstrating the robot’s performance.
- ▶️ Mechanism Test 1 (Google Drive)
- ▶️ Mechanism Test 2 (Google Drive)
- ▶️ Prototype Test (Google Drive)
- ▶️ R2 Test (Google Drive)
- ▶️ Damping Prototype test Footage (Google Drive)
- ▶️ Jump test on Arena with Controlled Damping (Google Drive)
📸 Gallery & Certification
| Robot 1 |
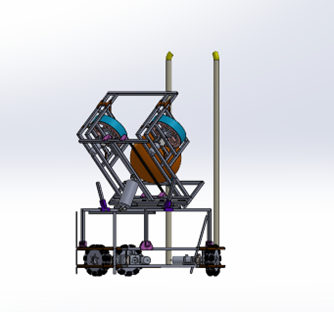 Robot 2 |
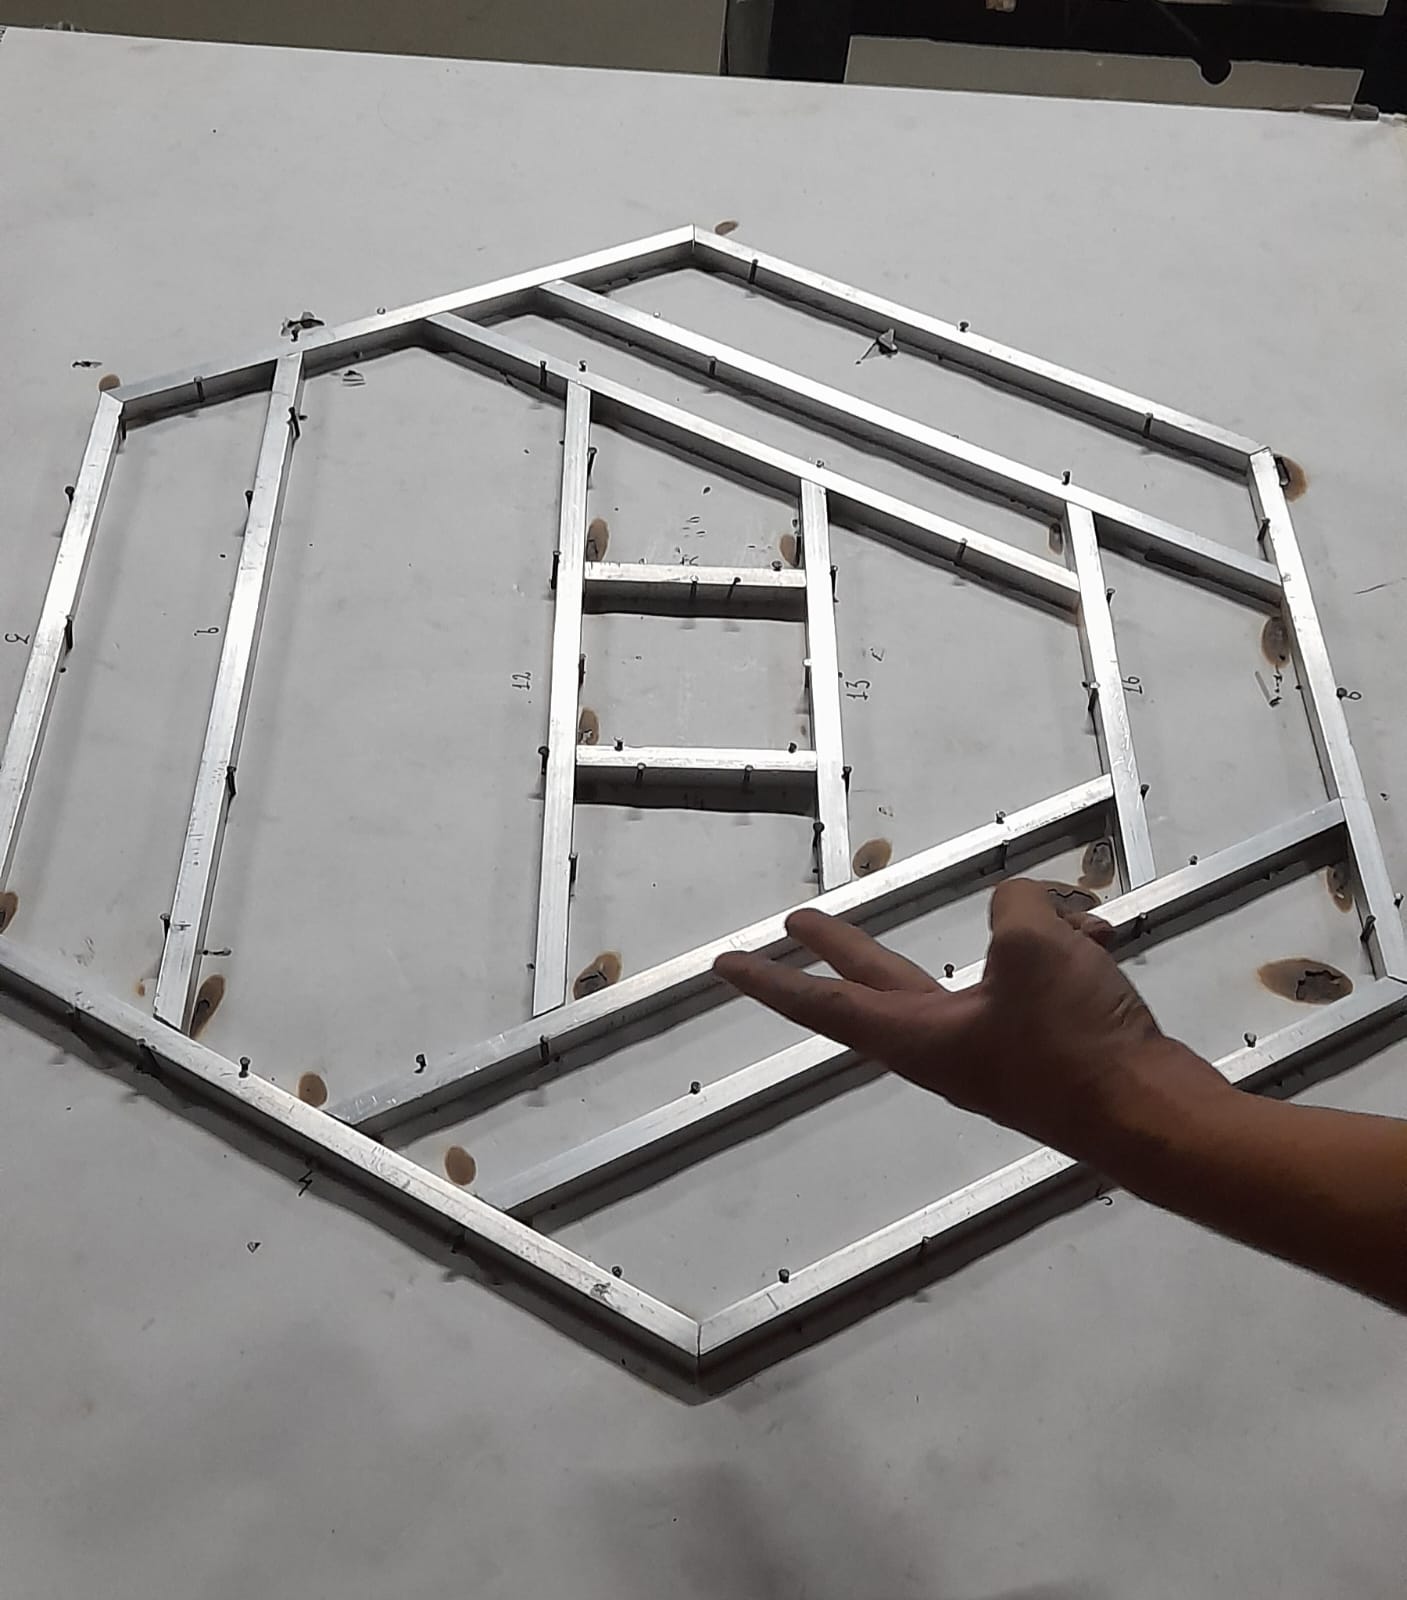 Aluminum Chassis Fabrication |
📄 View Certificate (PDF) League Qualification |
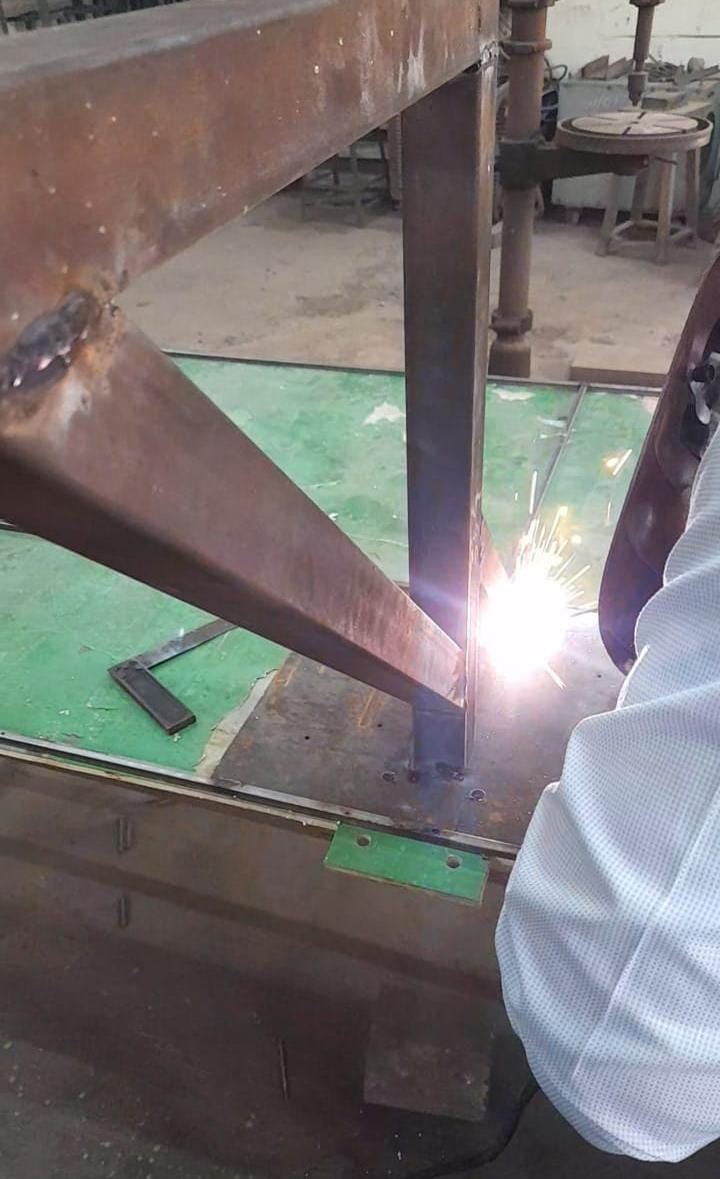
Welding the structure for Basket
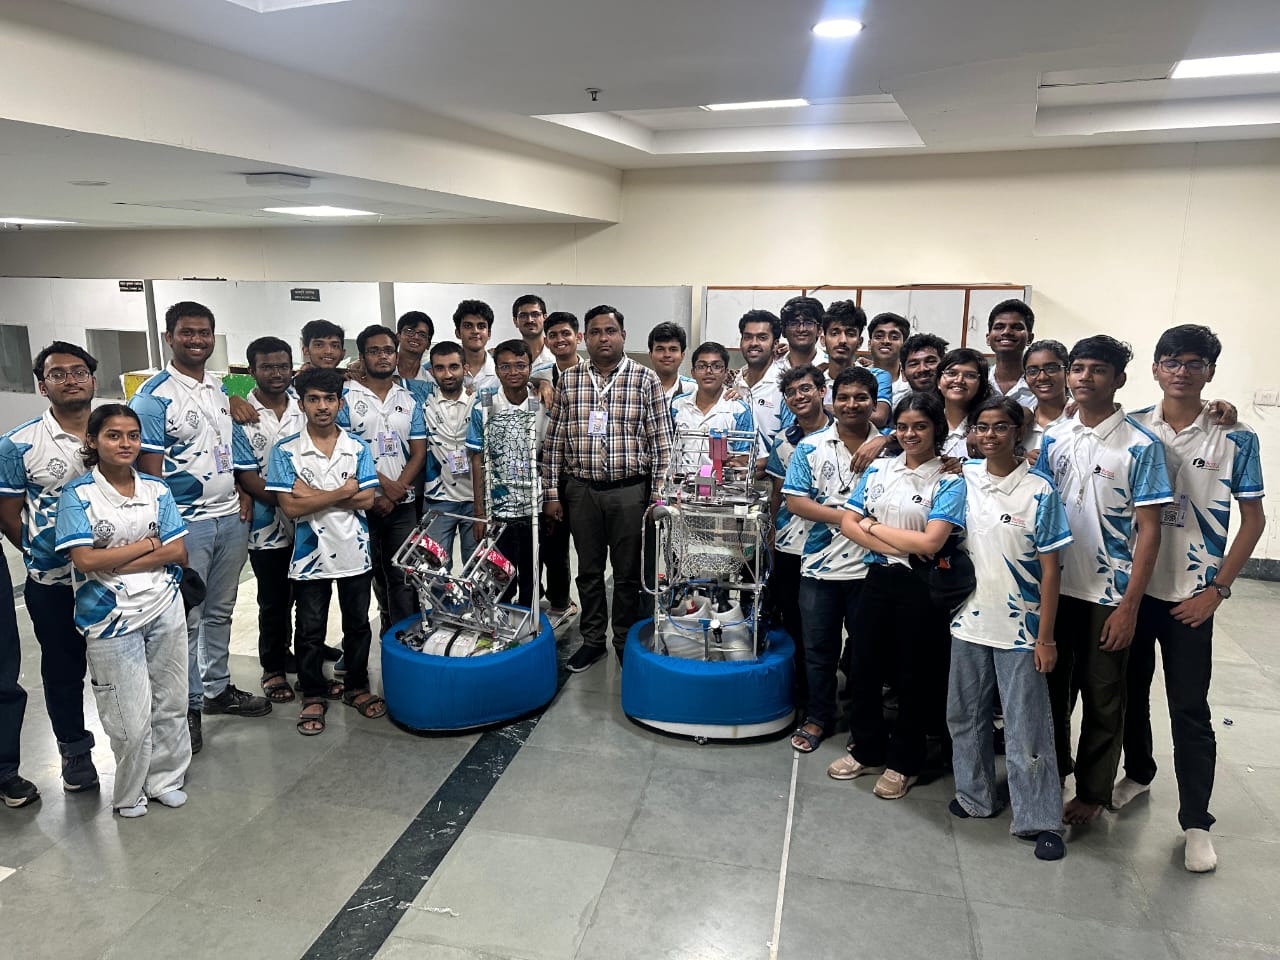
Team!!!